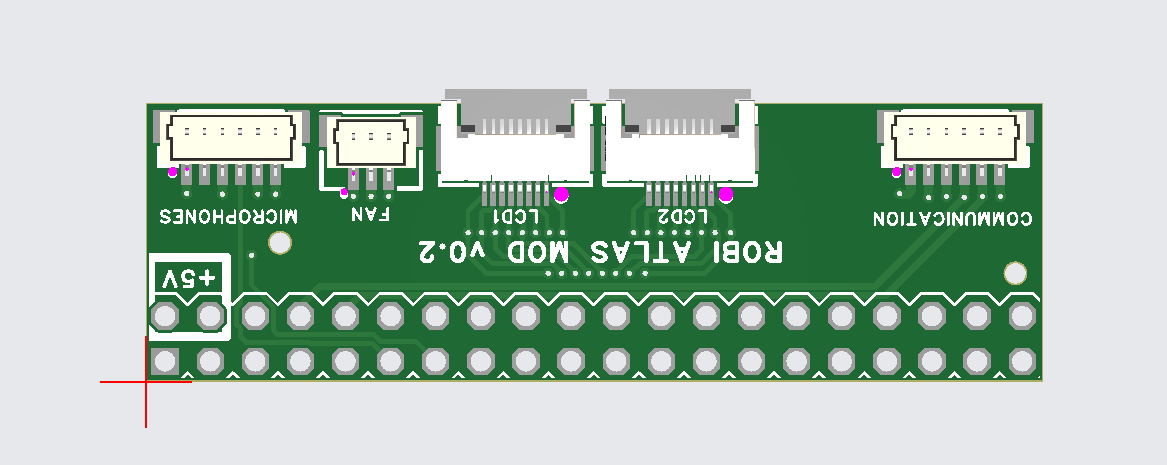
What is the Atlas Mod?
This project is where I apply new knowledge in order to develop a complete robotics platform using the generation 1 Robis as a chasis. This will allow me to expand into building completely new robots and hardware. This also serves as a platform for me to try new AI architectures and research robot embodiment.
Visit the Repository
Currently I am working on a new microcrontroller and tidying up some wiring before expanding the basic software I've built.
Why would this matter?
lorem ipsum
Initial Prototyping
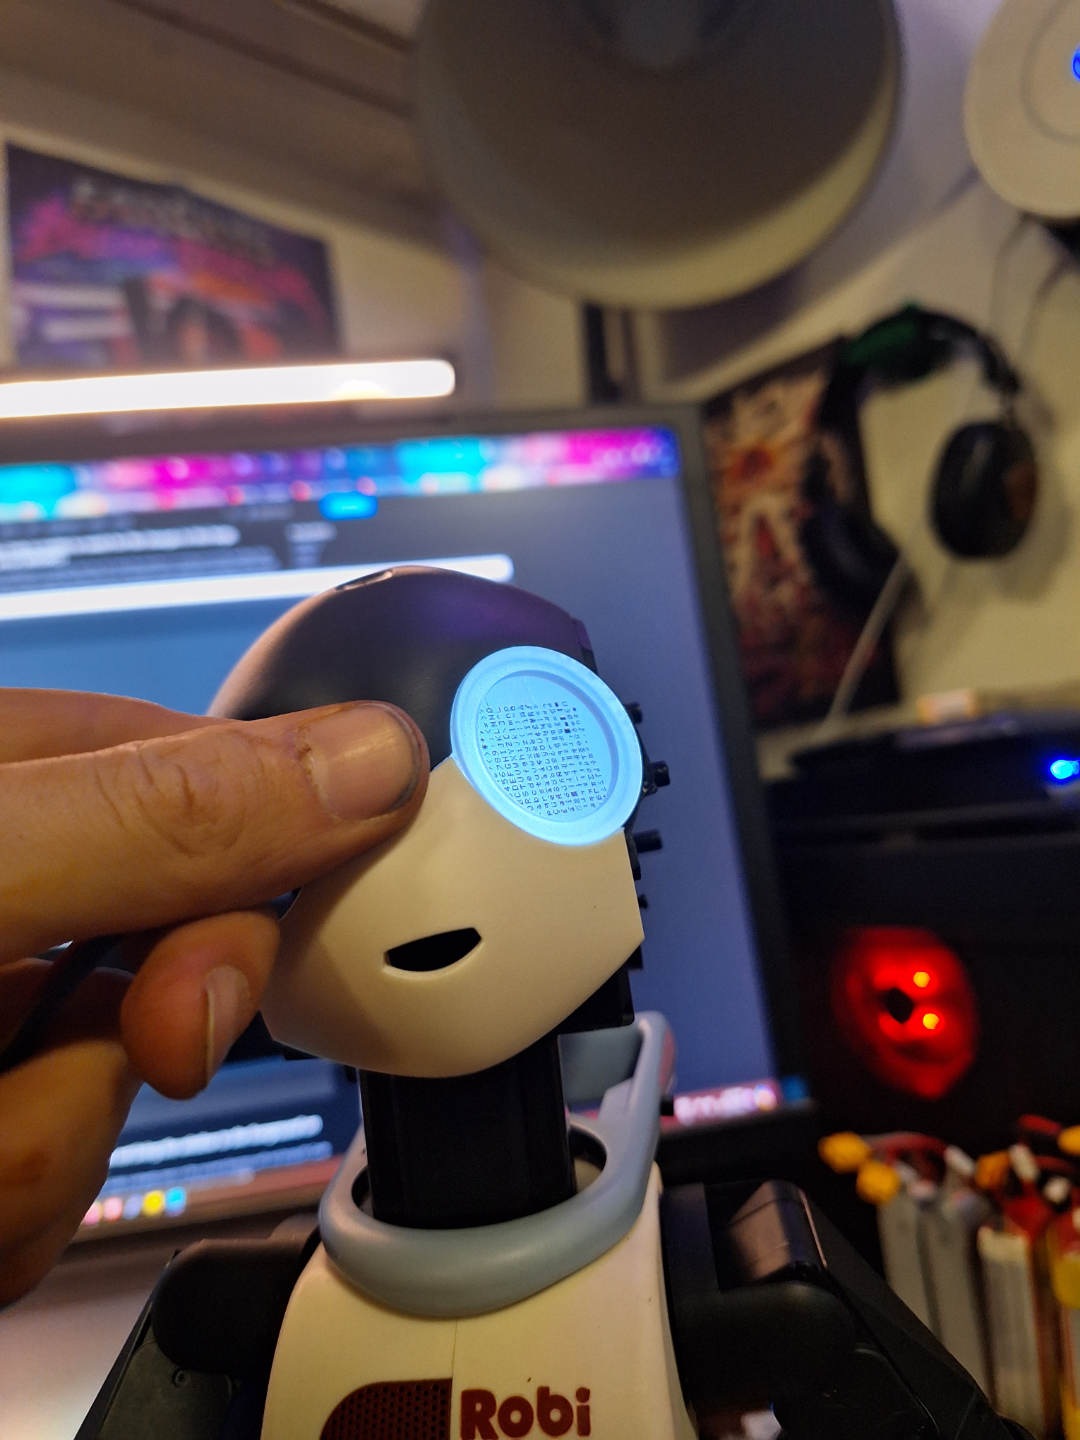
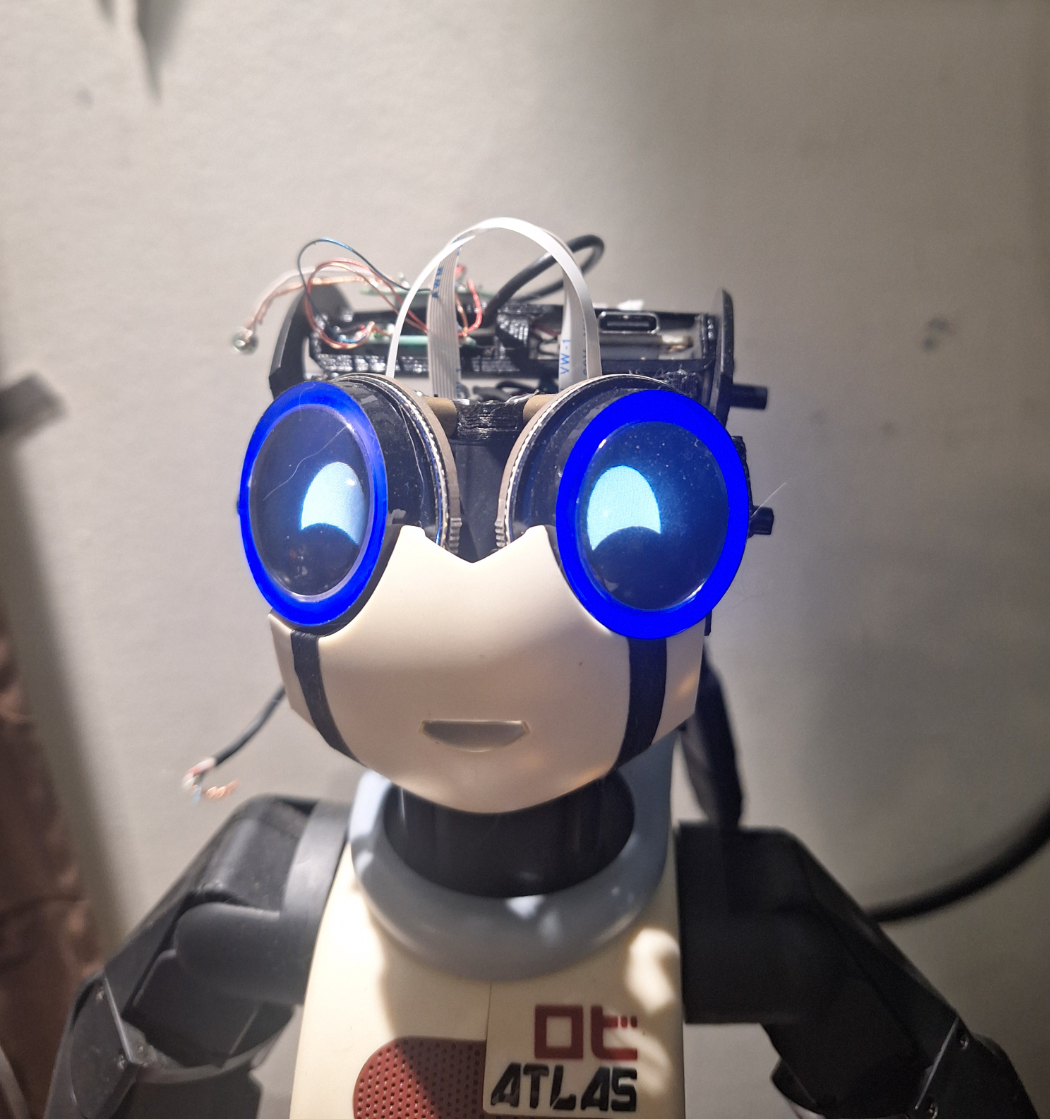
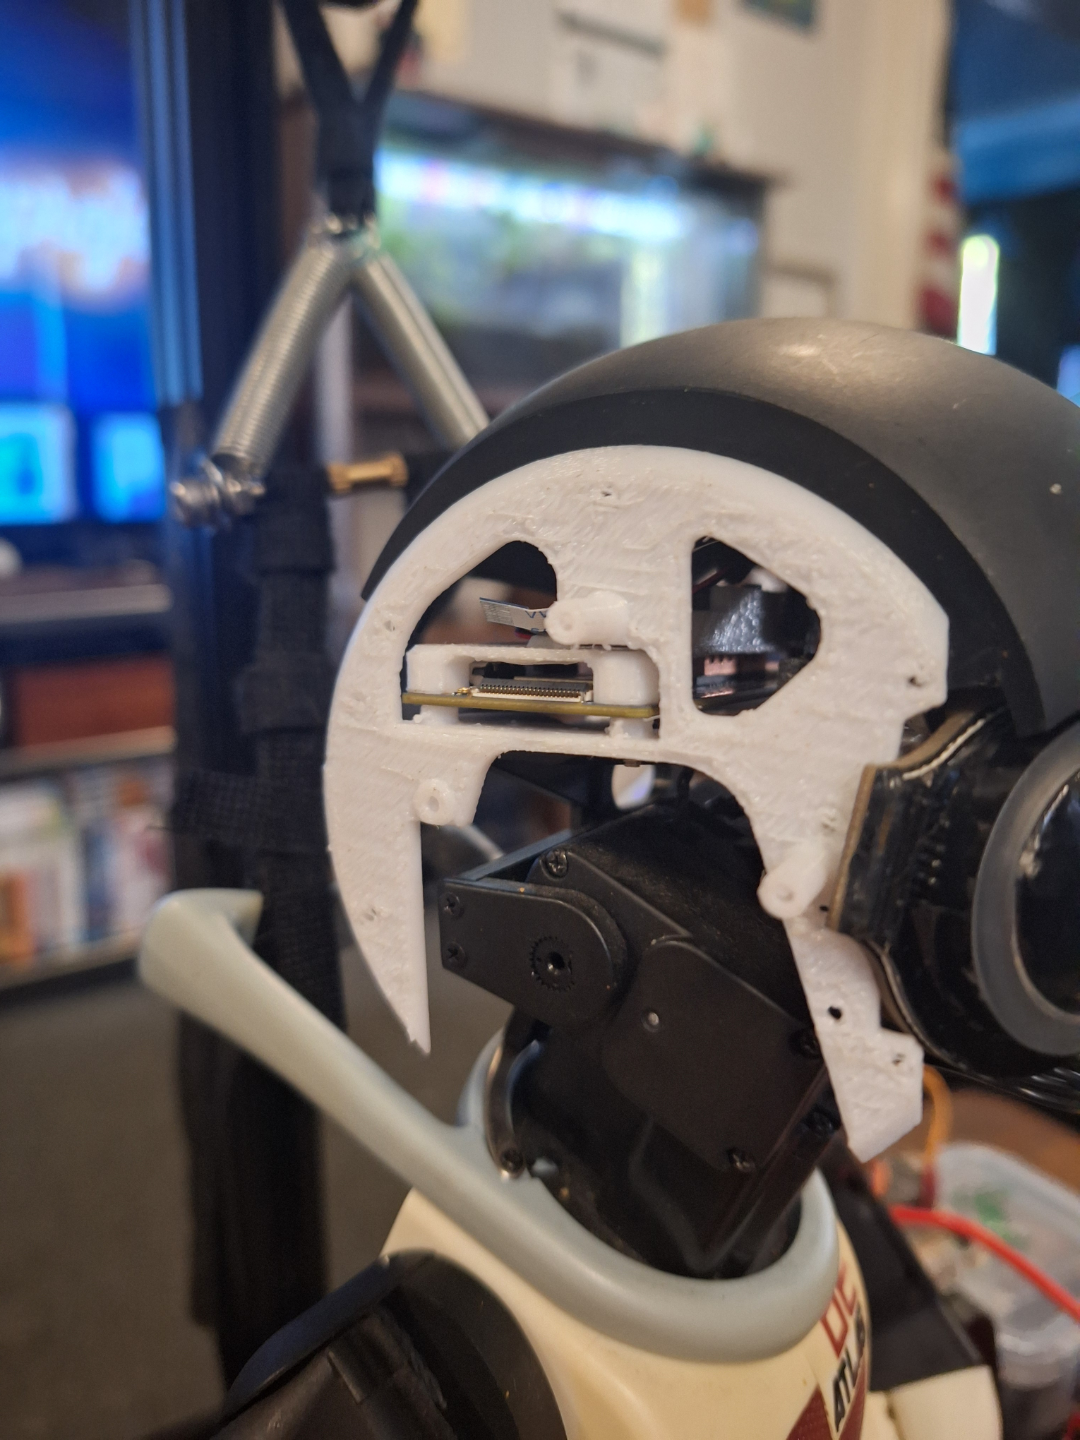
I started by creating an upgrade for the eyes that use round LCDs to allow further expression, these tie into a SBC, initially I started with a Raspberry Pi Zero 2w however the limited ram created issues. The current SBC is the Orangepi Zero 2w 4G, optimally I'd like to use a 8GB or 16GB Radxa Zero but for the sake of development cost, the Orangepi will do.
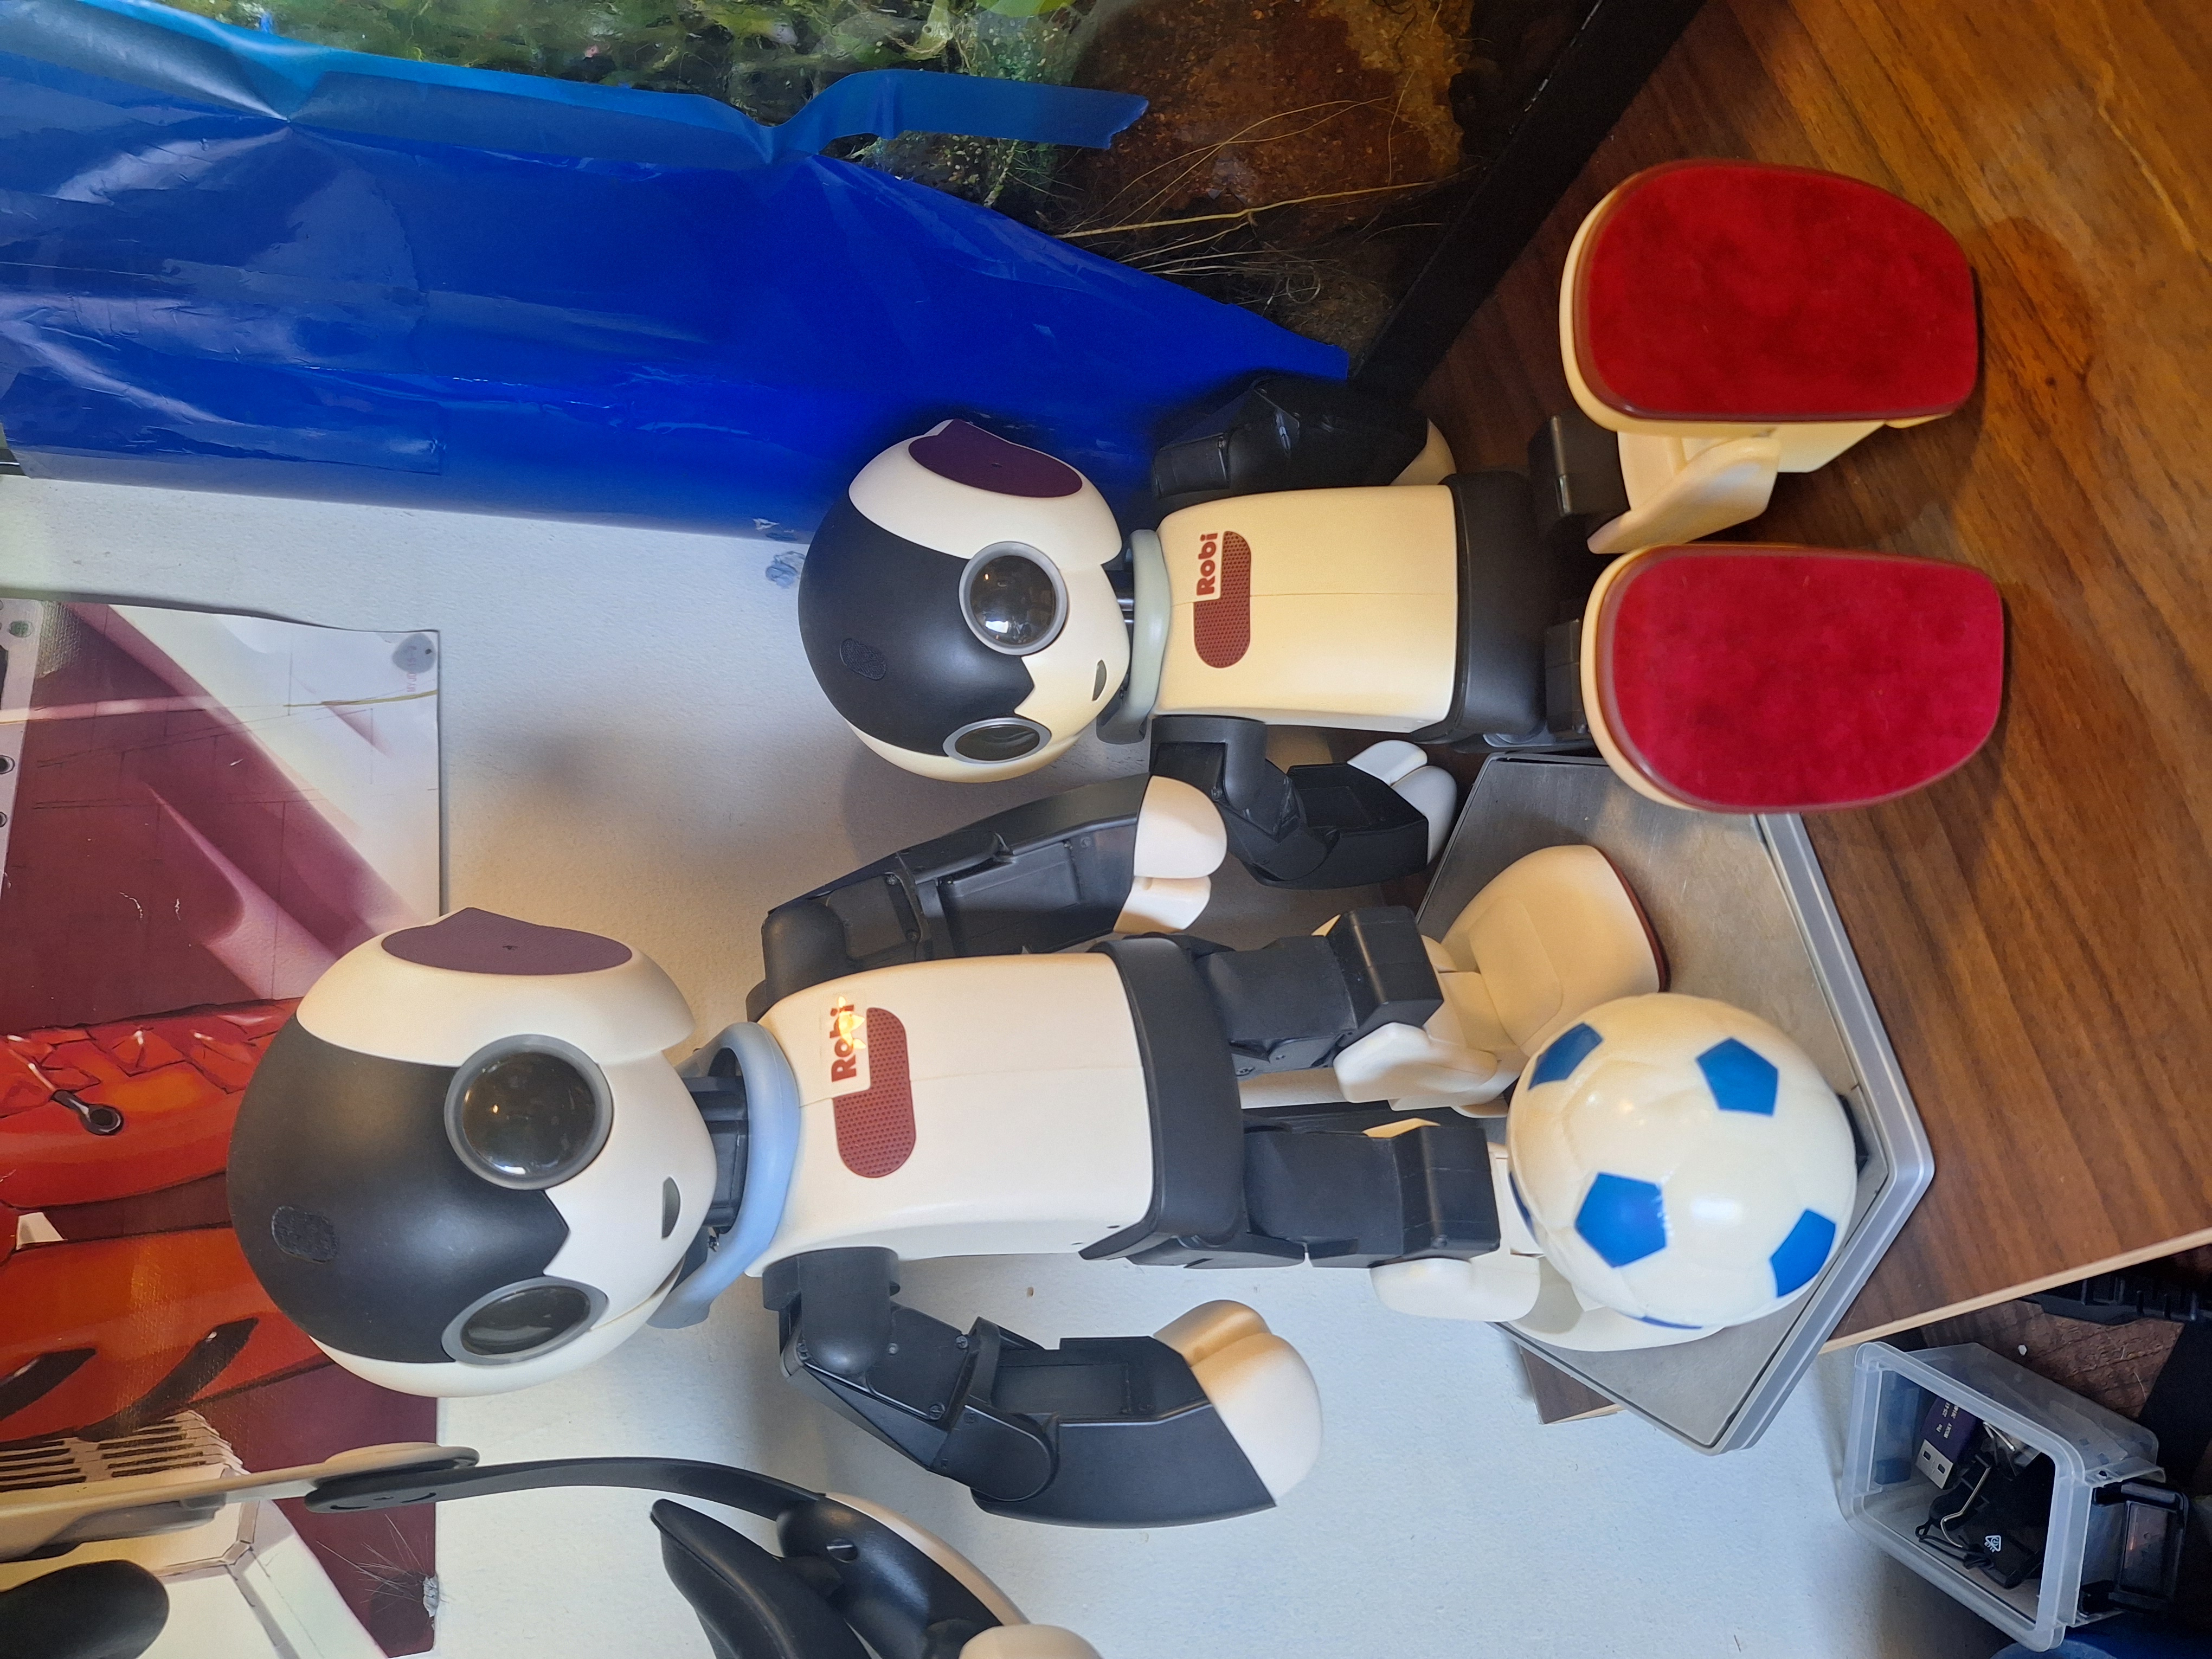
Prototyping New Hardware
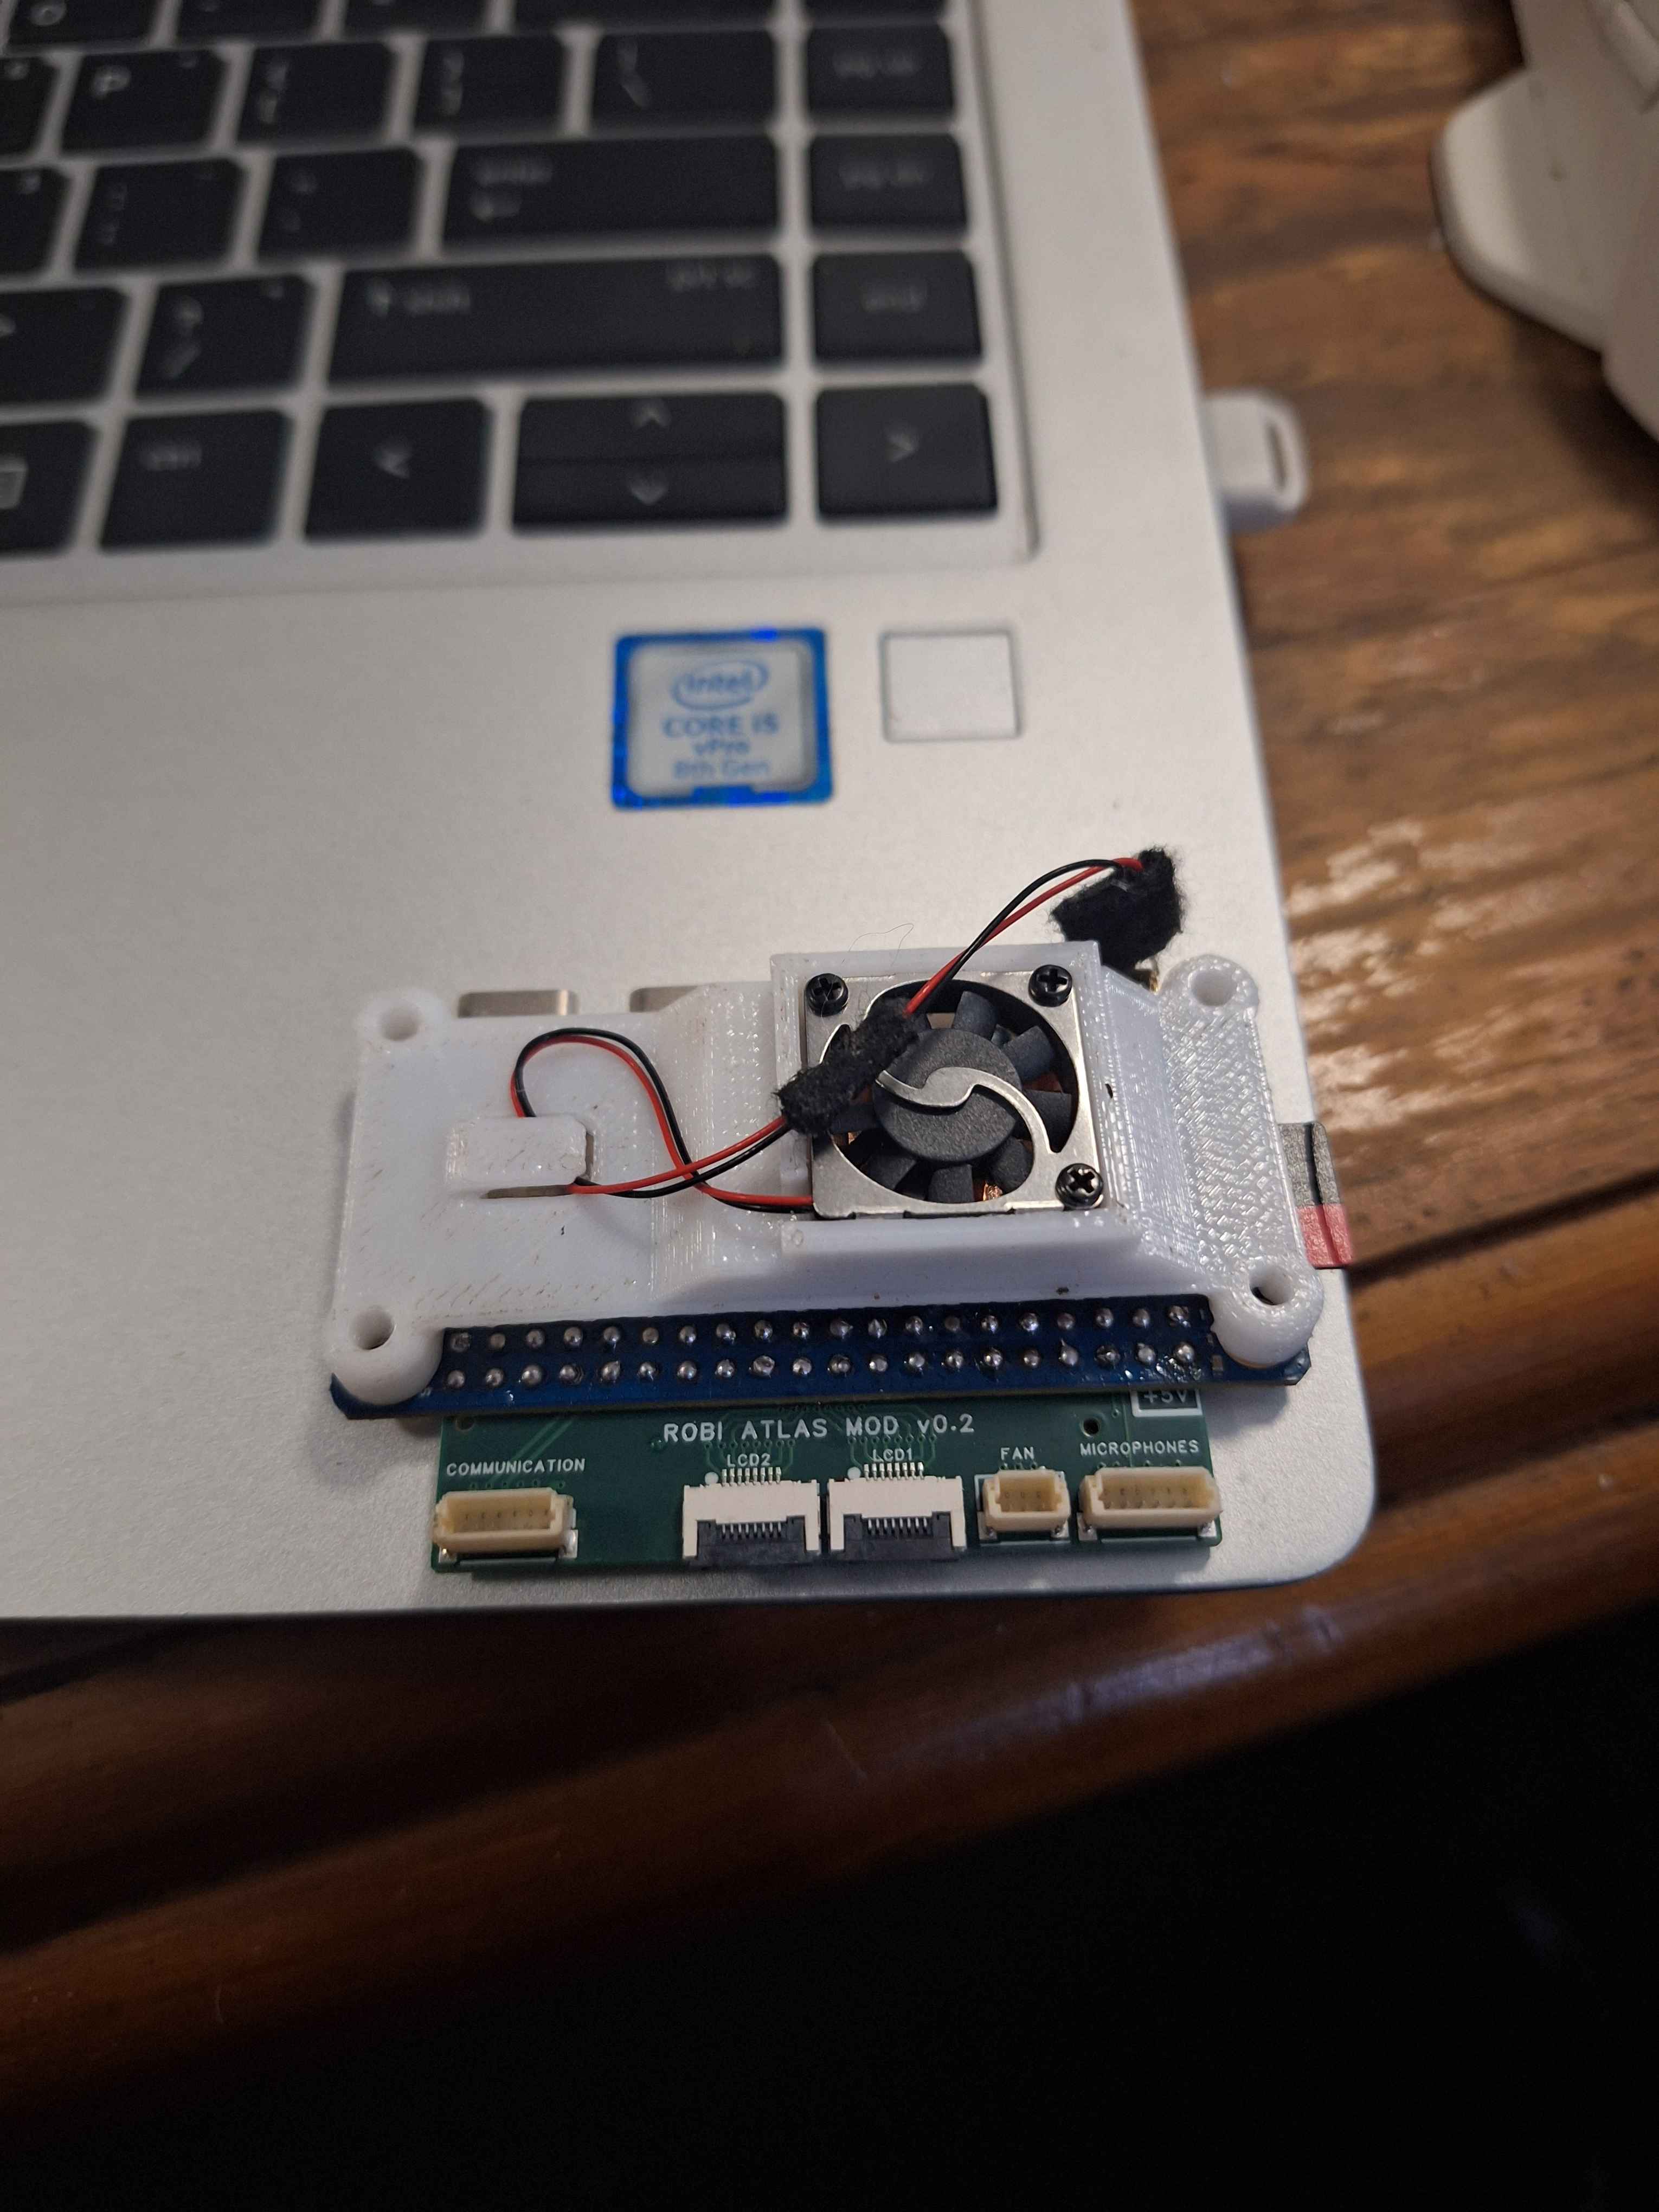
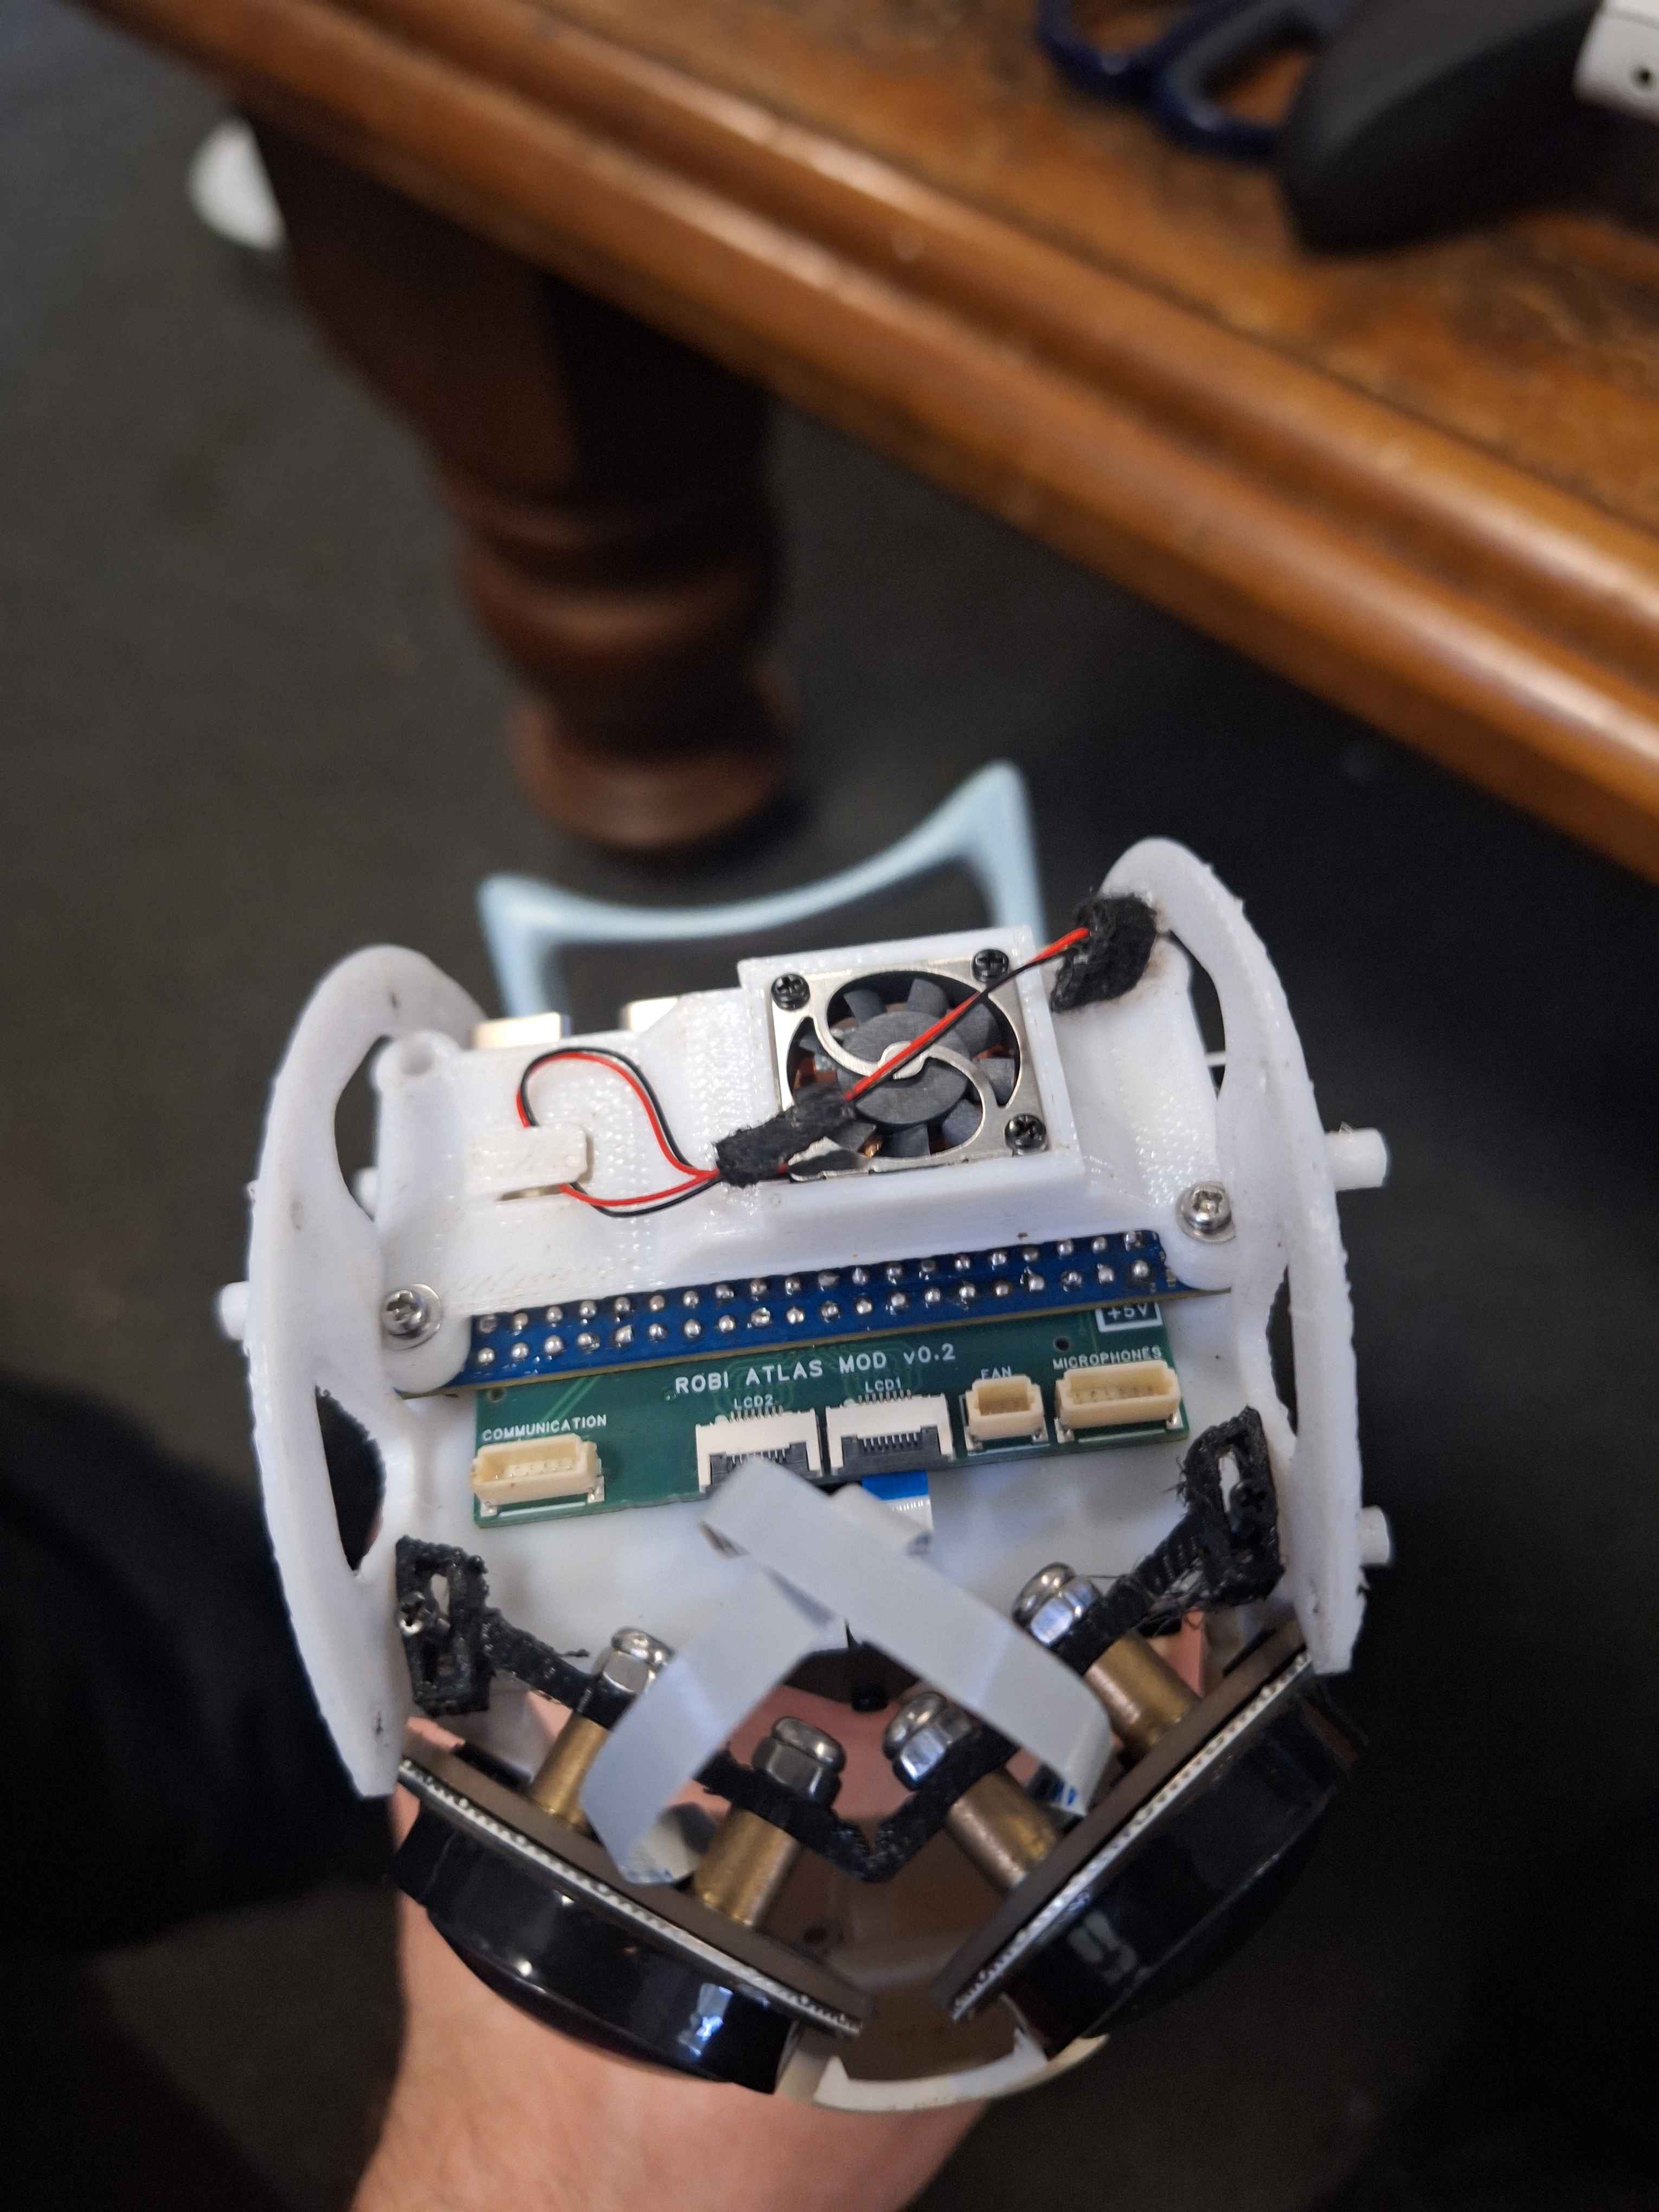
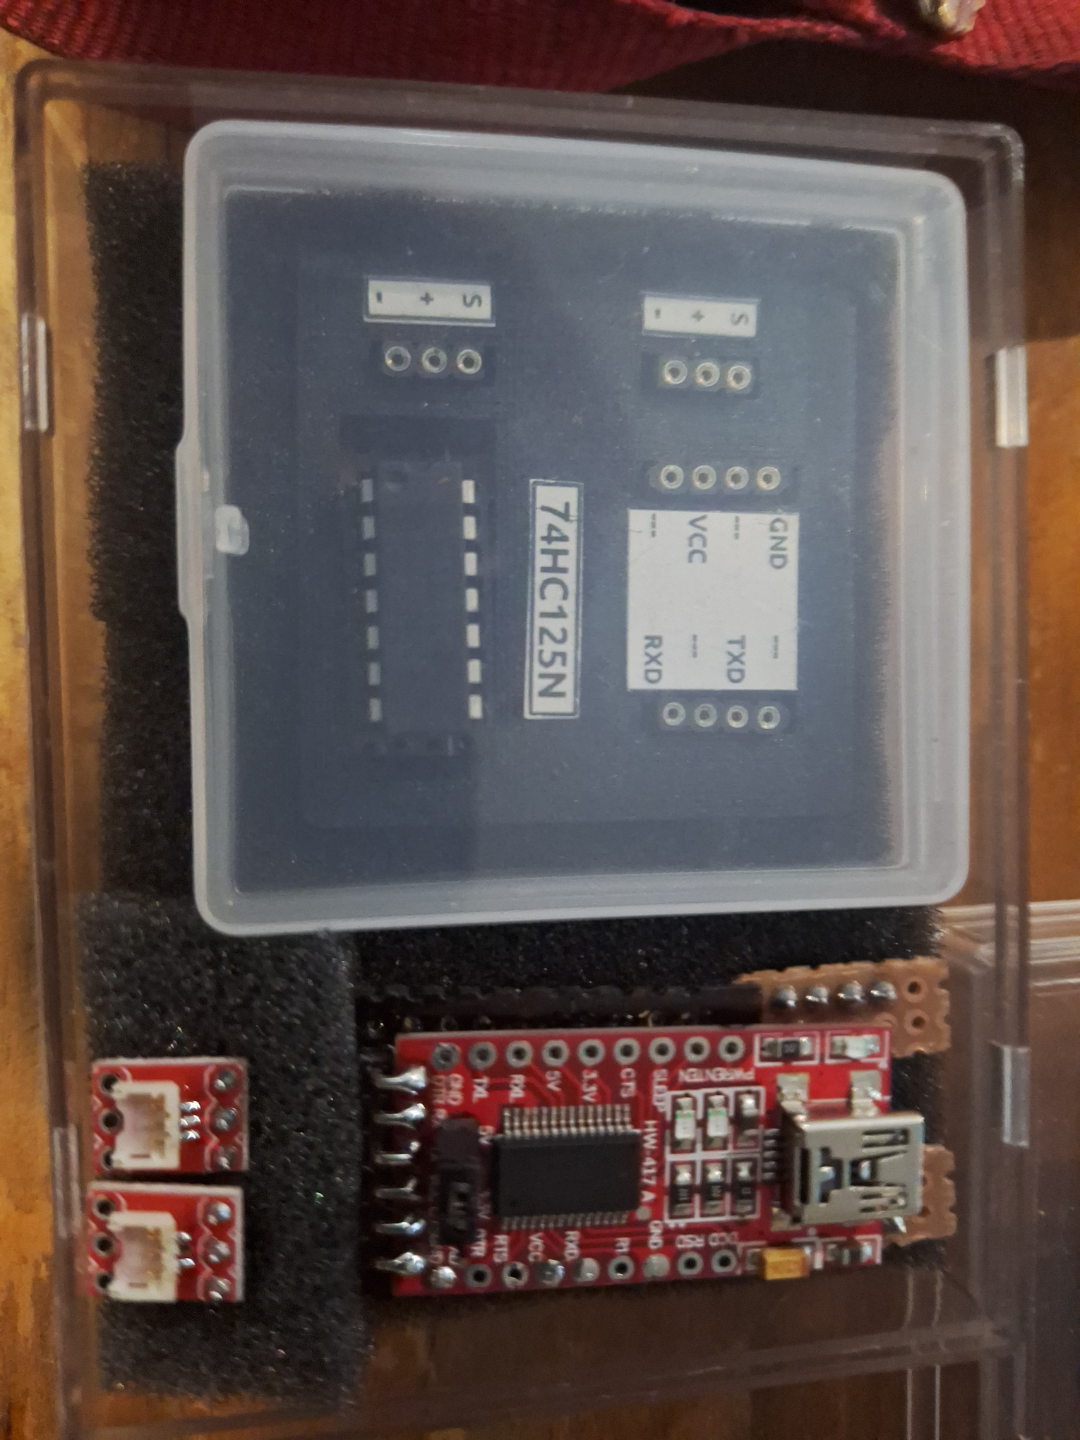
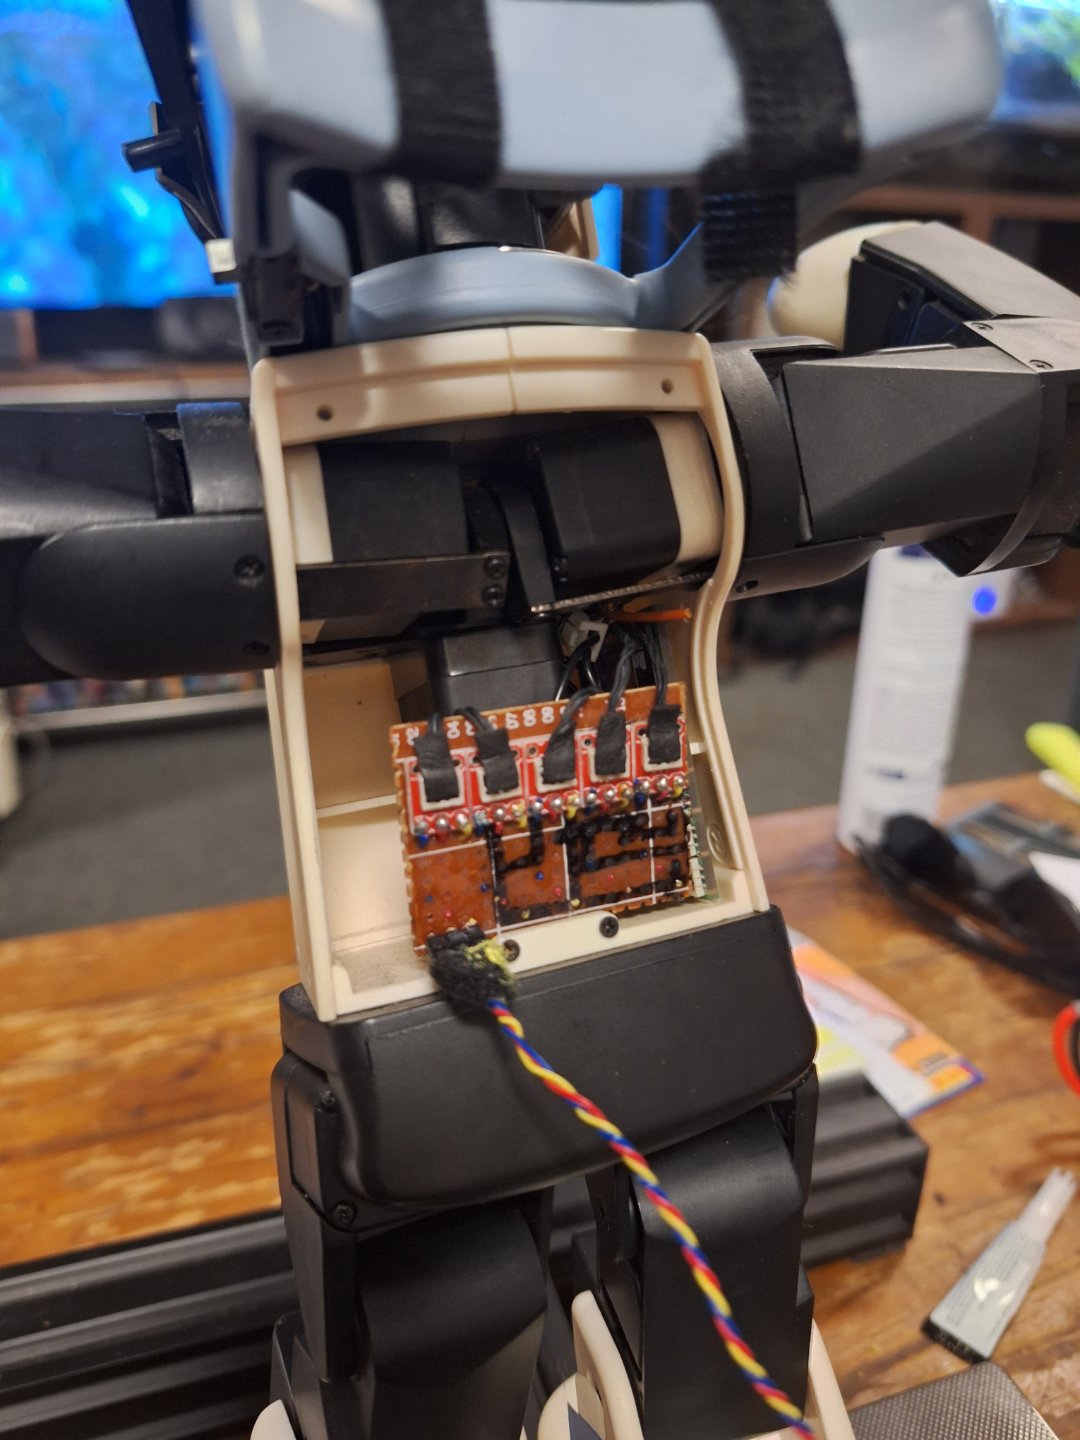
The images here show various parts and stages of the robot, this is when I spend the most time figuring out optimal setups and plan for hardware consolidation with professionally manufactured PCBs
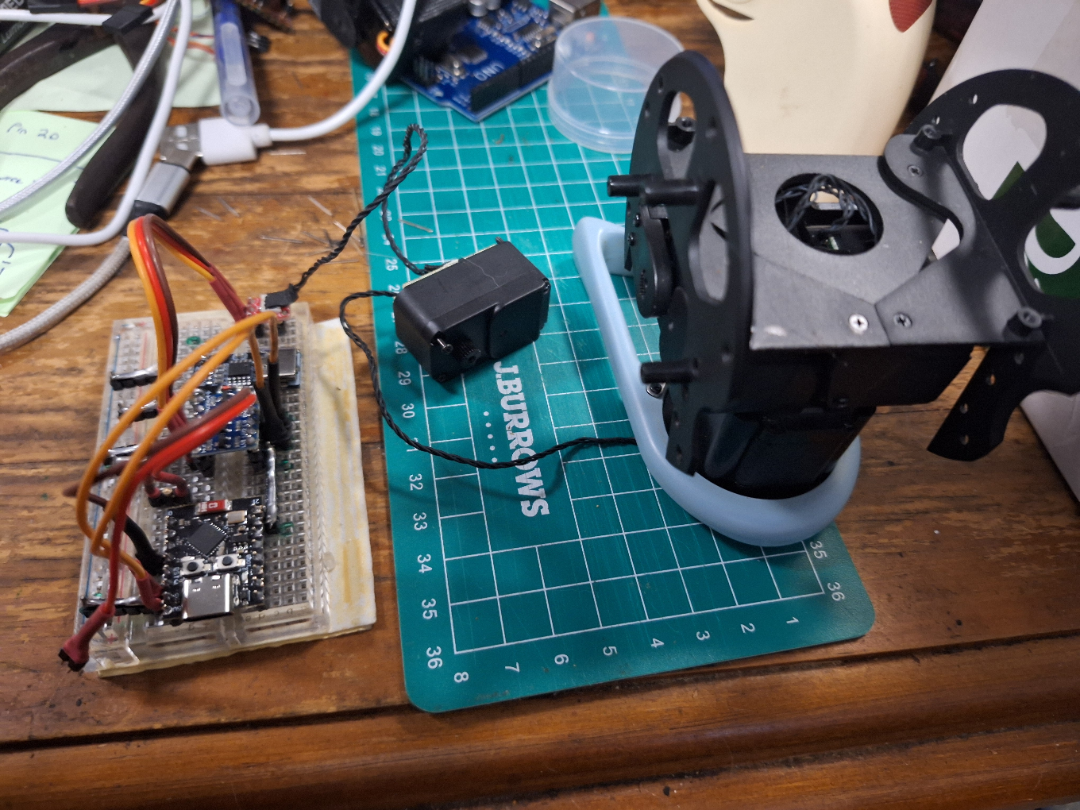
Initial Hardware Revision and consolidation
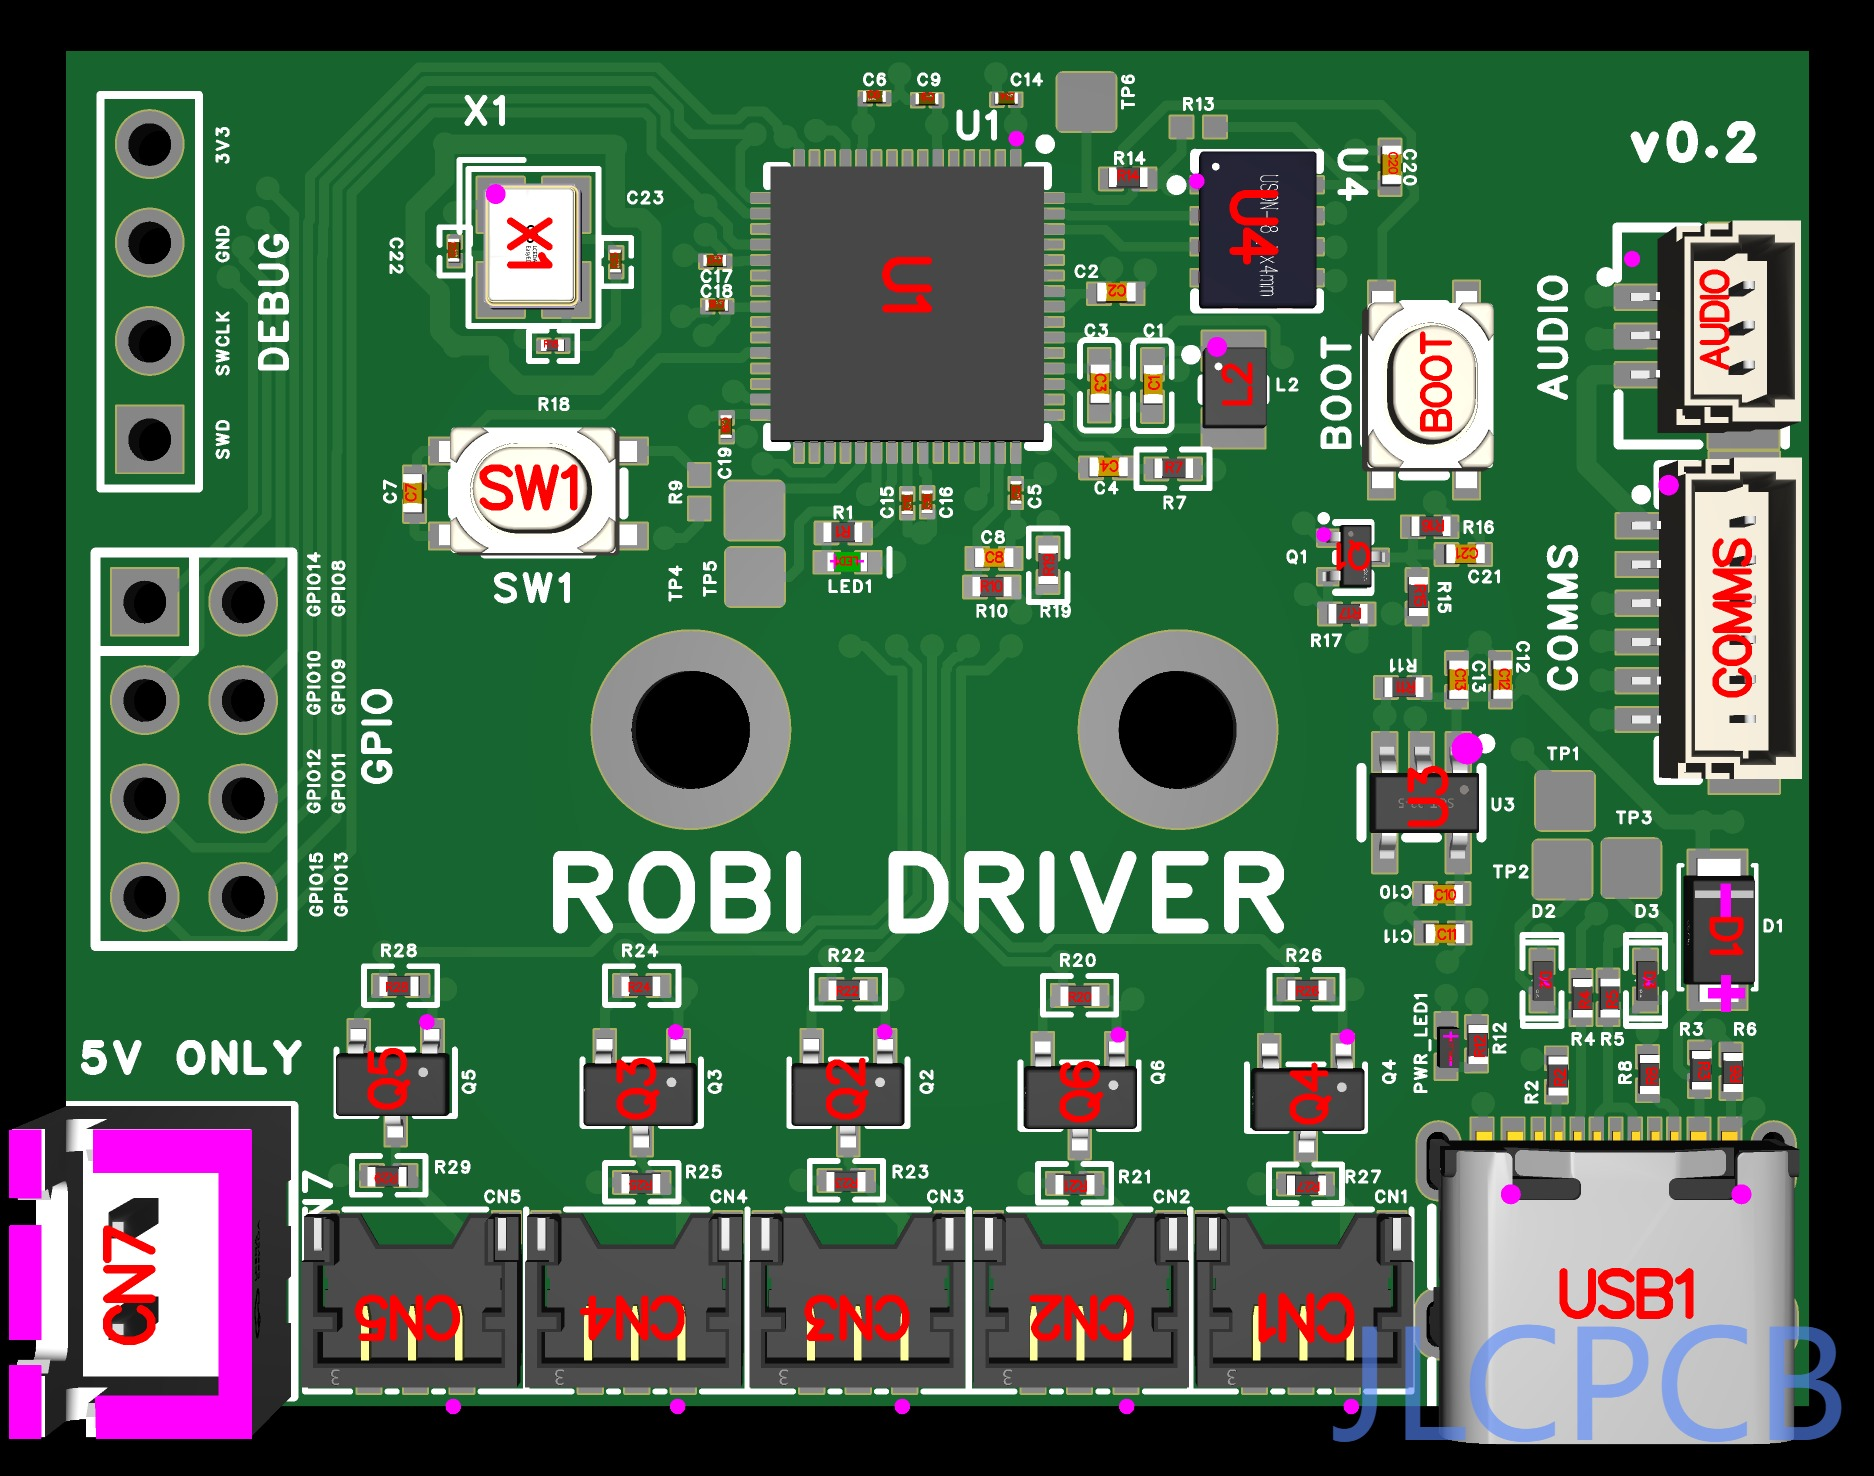
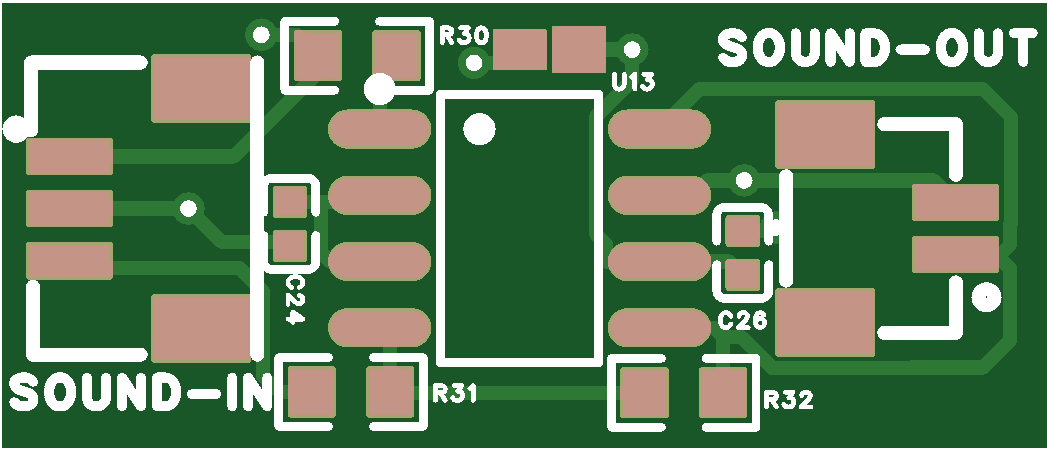
This is the first tests with a custom PCB I designed after prototyping with SPI flex connector breakout. Alongside a new cooling shroud design using an 18mm fan and copper heatsinks. Additionally there is a small audio amplifier and custom RP2350 driver board using PIO pins for servo communication.